|
I am a third-year undergraduate student at Nanyang
Technological University (NTU), Singapore. My research interests lie in
Generative AI, with applications in world models and robotics.
I am currently doing research on 3D/world models at the Spatial Intelligence Lab, advised
by Prof. Jiawang Bian.
I am also an algorithm engineer intern at ByteDance, working on AIGC.
|
|
|
|
|
|
|
* Equal contribution / † Corresponding author |
|
|
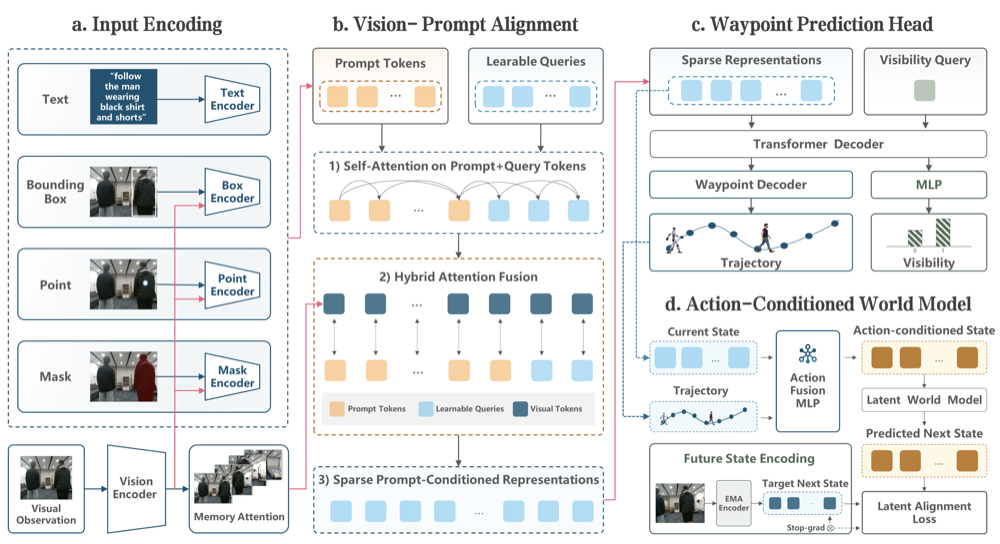
Yuchen Xie*, Xinyu Zhou*, Kuangji Zuo, Yanshuo Lu, Fengrui Huang, Boyu Ma, Jianfei Yang† Paper / Project USS lets a robot follow a target specified by text, a point, a box or a mask, mapping any of these prompts to egocentric waypoints end to end. Policies trained only in simulation transfer zero-shot to a real humanoid robot across 320 real-world trials. |
|
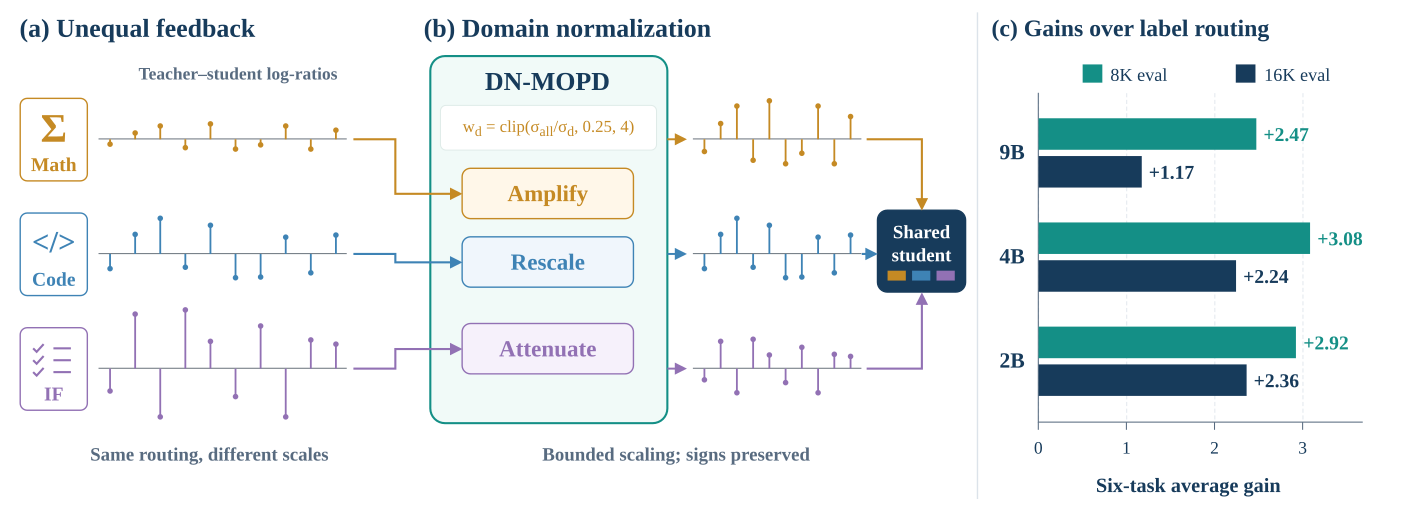
Xin Li, Hao Jiang, Xin Gao, Annan Wang, Yuchen Xie, Jinghao Guo, Xingwei Qu, Yichi Zhang, Chau Yuen Paper / Project DN-MOPD keeps label routing in multi-teacher on-policy distillation but rescales each domain's teacher feedback by its measured spread, so that no single domain dominates the shared student. |
|
|
|
|
|
ByteDance
2026.04 - Present Algorithm Engineer Intern, AIGC |
|
|
Whale Cloud
2025.05 - 2025.08 Computer Vision Algorithm Engineer Intern |
|
|
Nanyang Technological
University
2024.08 - Present Undergraduate Researcher at Spatial Intelligence Lab, advised by Prof. Jiawang Bian Undergraduate Researcher at MARS Lab, advised by Prof. Jianfei Yang |
|
|
This template is a modification to Jon Barron's website. |